|
Candy
|


All Classes Namespaces Files Functions Variables Typedefs Enumerations Enumerator Friends Groups Pages
|
Candy
|
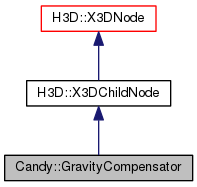
Public Member Functions | |
| void | traverseSG (H3D::TraverseInfo &ti) |
| void | initialize () |
Public Attributes | |
| std::auto_ptr< H3D::SFFloat > | kInit |
| std::auto_ptr< H3D::SFFloat > | errorPeak |
| std::auto_ptr< H3D::SFFloat > | alpha |
| std::auto_ptr< H3D::SFFloat > | beta |
| std::auto_ptr< H3D::MFVec3f > | position |
| The positions to sample gravity compensation over. More... | |
| std::auto_ptr< H3D::SFString > | storeFile |
| The file to use as gravity compensation data store. More... | |
| std::auto_ptr< H3D::SFInt32 > | state |
| The current state of the gravity compensating algorithm. More... | |
| std::auto_ptr< H3D::SFInt32 > | deviceIndex |
| std::auto_ptr< H3D::SFFloat > | gravityEstimationTime |
| The number of seconds the device has to be stationary to be considered static. More... | |
| std::auto_ptr< H3D::SFFloat > | gravityEpsilon |
| The tolerated error in gravity estimation. More... | |
| std::auto_ptr< H3D::SFFloat > | delaunayEpsilon |
| The epsilon used to check if a set of points are associated with the same circumcircle. More... | |
| std::auto_ptr< H3D::MFInt32 > | coordIndex |
| Delaunay structure for debugging. More... | |
| std::auto_ptr< H3D::MFVec3f > | point |
| Delaunay points for debugging. More... | |
Static Public Attributes | |
| static H3D::H3DNodeDatabase | database |
| std::auto_ptr<H3D::MFInt32> Candy::GravityCompensator::coordIndex |
Delaunay structure for debugging.
| std::auto_ptr<H3D::SFFloat> Candy::GravityCompensator::delaunayEpsilon |
The epsilon used to check if a set of points are associated with the same circumcircle.
| std::auto_ptr<H3D::SFFloat> Candy::GravityCompensator::gravityEpsilon |
The tolerated error in gravity estimation.
Measuring errors caused by device friction will cause the gravity estimation to never converge if this is set too low.
| std::auto_ptr<H3D::SFFloat> Candy::GravityCompensator::gravityEstimationTime |
The number of seconds the device has to be stationary to be considered static.
| std::auto_ptr<H3D::MFVec3f> Candy::GravityCompensator::point |
Delaunay points for debugging.
| std::auto_ptr<H3D::MFVec3f> Candy::GravityCompensator::position |
The positions to sample gravity compensation over.
If this is set the algorithm will estimate the compensation required and write to the file specified by storeFile.
| std::auto_ptr<H3D::SFInt32> Candy::GravityCompensator::state |
The current state of the gravity compensating algorithm.
| std::auto_ptr<H3D::SFString> Candy::GravityCompensator::storeFile |
The file to use as gravity compensation data store.
 1.8.6